Select a blog to read
Blogs
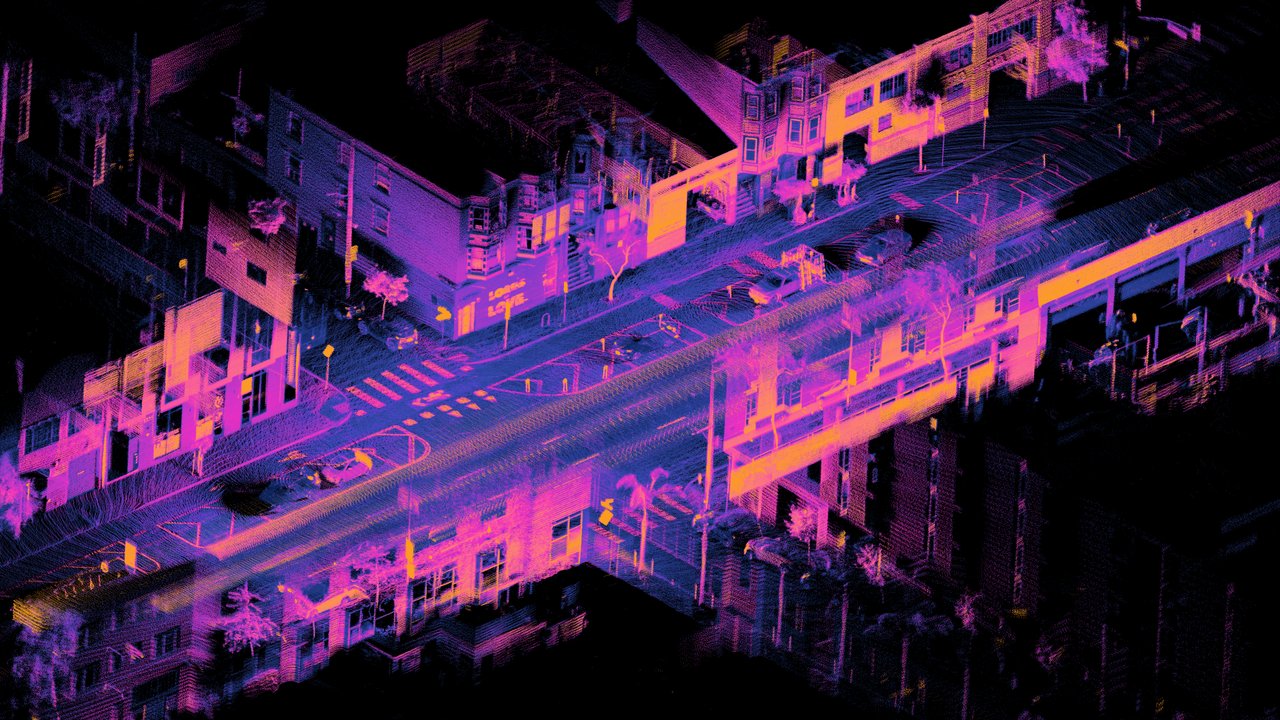
4. Does Simplicity Scale? Reproducing and Stress-Testing SimpleView for Point Cloud Classification
Can a simple 2D projection model really match complex 3D architectures on point cloud classification? We reproduce SimpleView, then push it onto new datasets, hyperparameter sweeps, inference optimizations and ablations.
3. Reading the Label, Not the Object: A Typographic-Distractor Control Dataset for CLIP-Based Robot Grasping
Does CLIP ground a robot’s language query in what an object looks like, or in text written in the scene? A controlled 400-image dataset built from real OCID-VLG scenes, and what it reveals about typographic attacks on CLIP-based grasping.
2. Reproducing GeoLanG: Geometry-Aware Language-Guided Grasping with Unified RGB-D Multimodal Learning
A from-scratch reproduction of GeoLanG, a model that uses language and depth to decide where a robot should grasp an object, plus ablations showing which of its modules actually help.
1. Delta Cup 2021 - A motivation to display an engineer's skills
Before checking out this post, please look up the Projects section to get an overview of my work. Why do you think I describe the Delta Cup as a test of an engineer’s skills? It is because, in my opinion, practical knowledge is a key asset for a person to be recognized as an engineer. But don’t get me wrong, I am not against theoretical knowledge. Theoretical learning is the foundation of any concept, but whether it can be applied in practice is a different question.