Acti-V-Link In-Hand Manipulation Gripper
Mar 2023 – Feb 2024
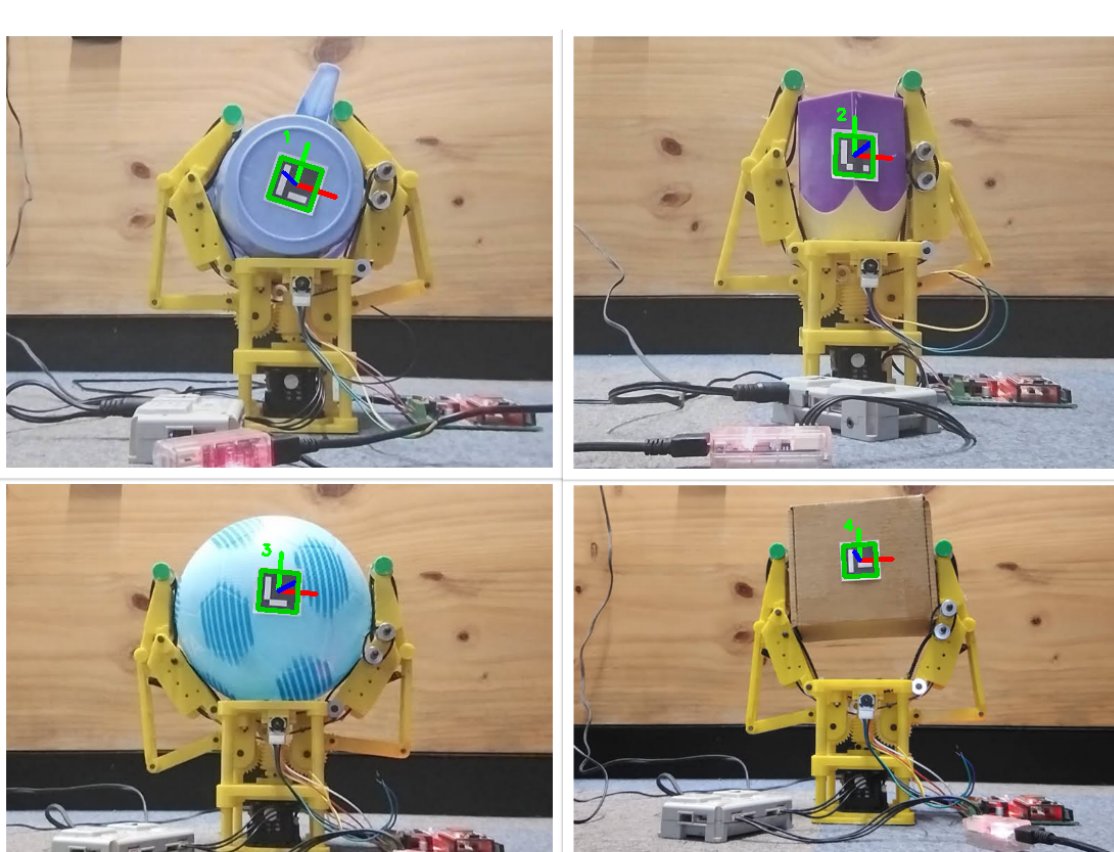
A low-cost, underactuated gripper with active surfaces that can rotate and translate objects in-hand, using visual feedback. The work was published at ACM RobCE 2024 and presented as a Spotlight Talk at the RSS 2024 Workshop on Dexterous Manipulation.
Direct supervisors: Prof. Vikas Phalle and Prof. Raju Tayade.
- Designed and analysed a novel underactuated, active-surface-based gripper for in-hand manipulation.
- Experimented with diverse transformations, such as rotation and translation, on objects of varying shapes through a closed-loop control system (bang-bang controller).
- Programmed the feedback system for grasping the object using DynamixelSDK, performing transformations with the help of ArUco markers and a webcam.
Visit the project page or watch the project video.