Project Reproduction: GeoLanG (ICRA 2026)
Feb – Apr 2026
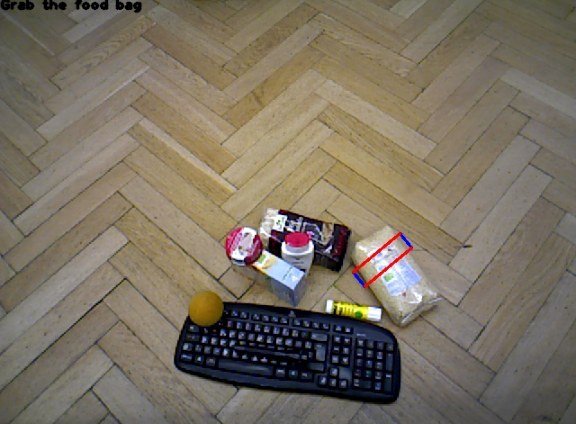
A reproduction of GeoLanG, a model that uses language and depth to decide where a robot should grasp an object in a cluttered scene, trained and evaluated on the OCID-VLG dataset.
- Reproduced and implemented the Multi-Modal Fusion Network (MFN) and the transformer-based Multi-Task Decoder for joint referring segmentation and grasp prediction.
- Conducted ablation studies and hyperparameter tuning on the Depth-Guided Geometric Module (DGGM), varying the decay rate to measure its impact on multi-scale feature suppression.
Read the full write-up in the project blog.
To check out our work click here