Mobile Manipulation for Indoor Cluttered Environment
Nov 2025 – Jan 2026
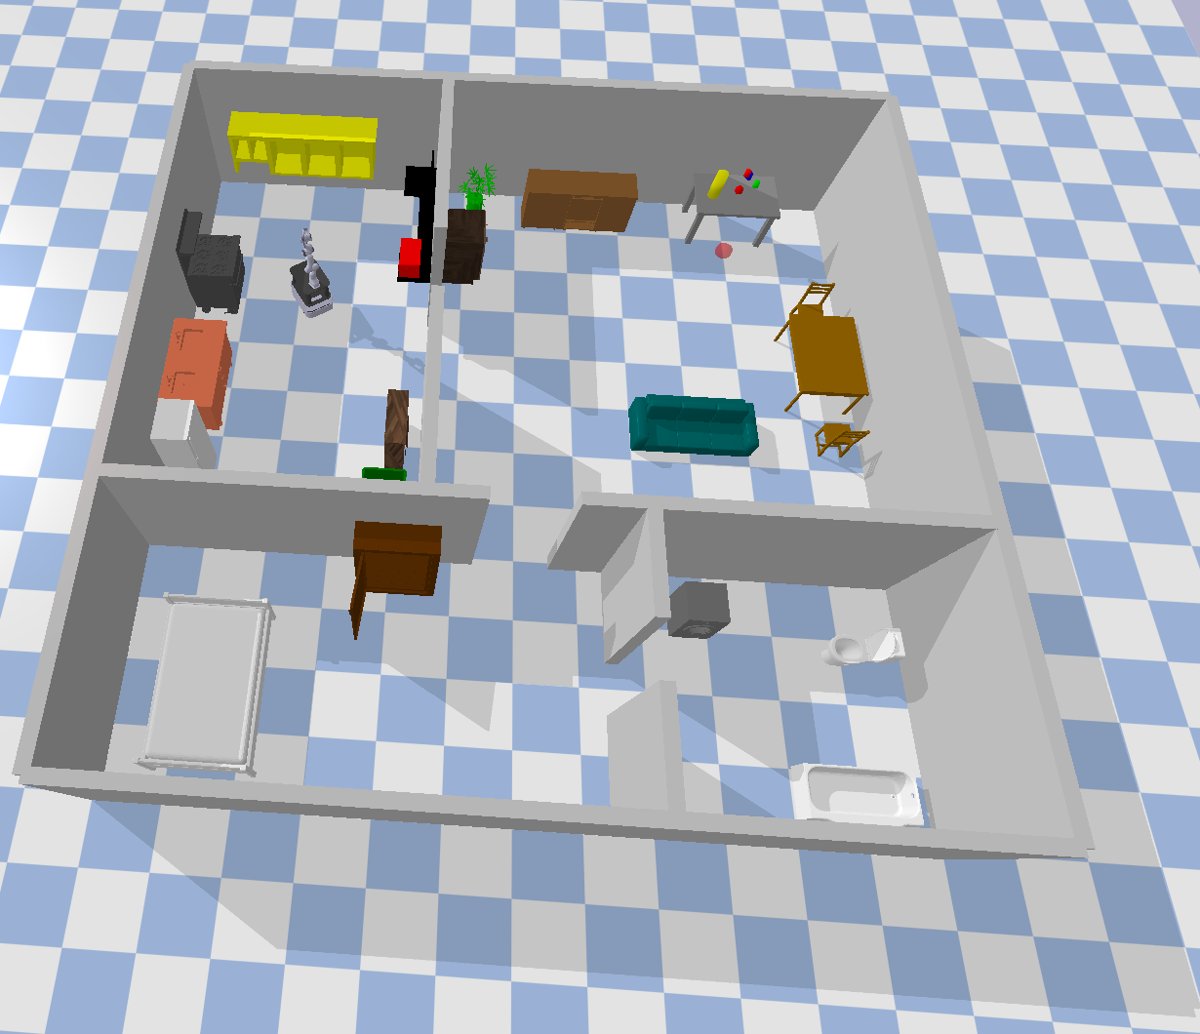
A planning framework for Albert, a mobile manipulator with a differential-drive base and a 7-DoF Franka Emika arm, to perform reliable pick-and-place tasks in cluttered indoor environments without colliding with obstacles.
- Built a decoupled, FSM-based planning pipeline that combines BIT* global planning for the base and the 7-DoF arm with MPC local planning for collision-free arm trajectory refinement.
- Benchmarked RRT*, RRT, RRTConnect and BIT* across three cluttered environments (home, supermarket and maze) and selected BIT* based on success rate and path cost.
To check out our work click here